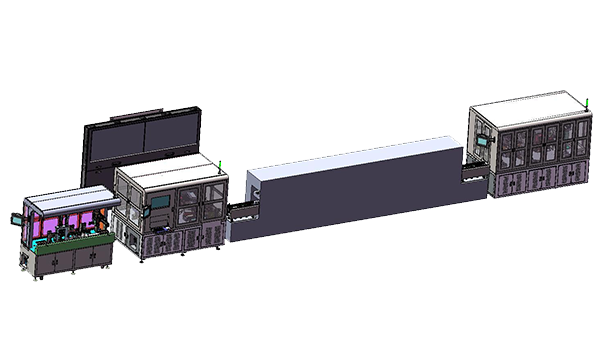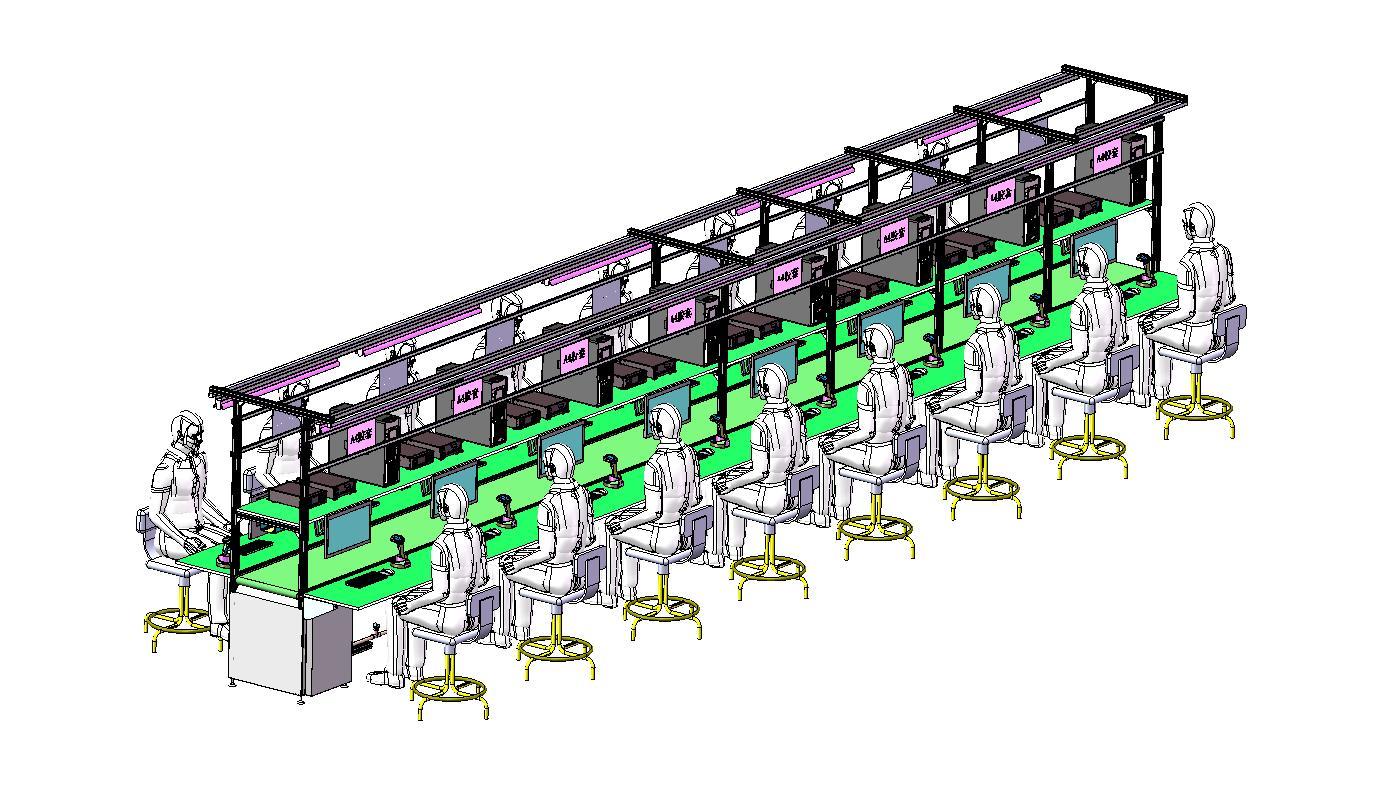
In this manual belt-line and AGV intralogistics layout project for the electronics industry, production remains strongly operator-based. Programming, Testing, DFU Test, Air-Pressure-Meter Operation, Image Review, and Appearance Inspection are arranged along a manual belt line, while intralogistics AGV solutions connect the Line Head and Line Tail with the surrounding material flow. The current line is approximately 17,000 mm long, and the layout reserves about 13,200 mm of depth for future expansion to three lines.
Human Passages and an Observation Passage are preserved between and beside the production lines. The layout therefore has to coordinate three movements at the same time: product movement along the belt, operator movement around each workstation, and AGV movement at the line interfaces.
Robotlyne’s Warehouse Automation Solutions can connect AGV / AMR systems, routes, transfer points, carriers, and upper-level control around this type of line-side logistics layout.
Follow the Product Through the Line Before Planning the AGV Route
The production sequence is arranged as Programming 1 → Test 1 → Programming 2 → DFU Test → Air-Pressure-Meter Operation → Image Review 1 → Image Review 2 → Appearance Inspection. These stations run continuously along a line of about 17 meters.
Short transfers between adjacent manual stations are handled most naturally by the belt line. Assigning an AGV to every short internal movement would create repeated task creation, docking, starting, stopping, and waiting over very small distances.
AGV → Line Head → Belt Line + Manual Operations → Line Tail → AGV
The belt therefore handles the dense internal movement, while the AGV handles the larger logistics jump between the production line and the surrounding workshop.
The Line Head and Line Tail Become the Two Main AGV Interfaces
For this manual production line, the Line Head is the point where material enters from the surrounding logistics system. The Line Tail is where completed products return to that system.
Those two interfaces determine where incoming material can wait, where finished products can accumulate, how the AGV approaches the line, and whether loading or unloading interferes with the normal walking path used by operators.
Buffers, fixed transfer positions, or other handoff equipment can then be arranged around these two points. AGV speed and navigation method are secondary to a stable physical handoff between the line and the vehicle.
The First Line Is Already Setting the Geometry for Lines Two and Three
The current layout already reserves a future Three-Line Layout with an overall depth of approximately 13,200 mm. Human Passages between the lines and an Observation Passage on one side remain part of that expansion plan.
The first line therefore establishes repeatable conditions for later lines: Line Head and Line Tail orientation, spacing between lines, AGV approach side, and passage locations. If those interfaces are kept consistent, the second and third lines can connect to the same logistics concept without creating a new approach pattern for every line.
The reserved expansion depth also protects the AGV aisle and operator access from being squeezed by future equipment. A compact first phase is useful only when it leaves enough space for the next two lines to repeat the same material-handoff geometry.
Manual Workstations Still Create Their Own Material-Handling Load
Operators remain responsible for most production work in this case. Each workstation includes items such as Operator Seats, Guide Documents, Lighting, Barcode Scanners, Test Instruments, Displays, Computer Hosts, Power Cabinets, and Utility Sockets.
Their arrangement affects the amount of micro-movement required at every cycle. A Barcode Scanner placed opposite the natural product-flow direction, or a Display separated from the test instrument, adds repeated turning and reaching even though the belt and AGV layout remain unchanged.
The Observation Passage supports the same operating reality. Quality staff, engineers, and maintenance personnel need access behind the line without interrupting the main operator path or the AGV interface. This becomes more important when three parallel lines are running.
A Scalable Layout Keeps the Same Handoff Logic as Capacity Expands
The 17-meter line, the Line Head and Line Tail, the human passages, the Observation Passage, and the reserved three-line depth together establish a repeatable logistics interface. Future lines can use the same material direction and AGV approach logic rather than creating new exceptions around each expansion phase.
Fleet capacity can then be sized against the actual production pattern using Production Rate, Transfer Frequency, Load Quantity, Travel Distance, and loading / unloading time. Those operating variables change how many vehicles are needed, while the line geometry and handoff interfaces remain stable.
If Programming, Testing, or Inspection stations are automated later, the same Line Head, Line Tail, AGV aisle, and expansion space can continue to support the line. The production technology inside the 17-meter route can evolve without forcing the surrounding intralogistics layout to be rebuilt.
If you are planning a new production line or expanding an existing electronics workshop, contact Robotlyne to review the line layout, Line Head / Line Tail interfaces, AGV approach, operator passages, and future expansion path.